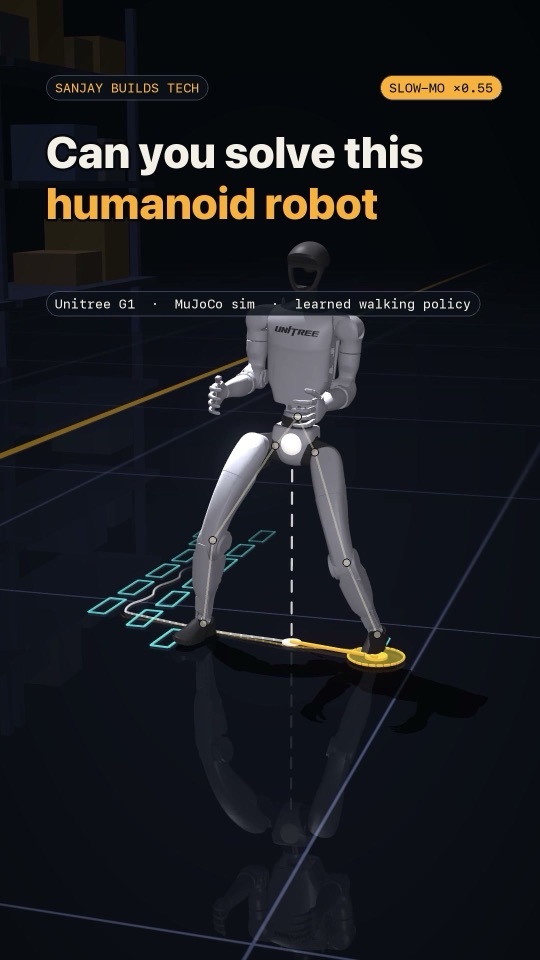
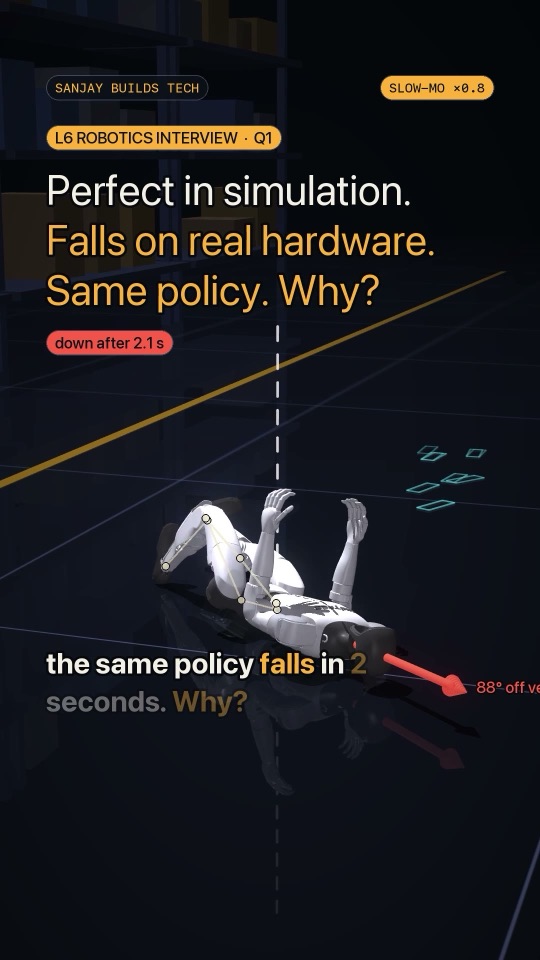
Play with itSpeed it up until the foot lets go
Worked solutionOne step at a time
Walking is vaulting
While one foot is planted, the leg is nearly straight, so the hip rides over the foot on a circular arc whose radius is the leg length L. That is an inverted pendulum.
Circles need a pull toward the centre
Anything moving at speed v round a circle of radius L needs an acceleration v²/L toward the centre. At the top of the step the centre is straight down, at the foot.
Gravity is the only thing pulling down
A leg can push the body up but it cannot pull it down (the foot is not glued to the floor). So the most downward acceleration available is g. Ask for more and the body leaves the arc: the foot lifts off.
Solve for the speed
Answer: C, about 2.4 m/s
The ratio v²/(g·L) is called the Froude number. Walking is only possible below 1. Above it there must be a moment with both feet in the air, and that is the definition of running.
What the simulation showedThe real G1 stays far below the limit
The reel's robot is Unitree's G1 (32 kg) walking with Unitree's own learned policy. Its real leg, hip joint to sole, is 0.68 m, so the live numbers in the reel use 0.68 m while the quiz uses a round 0.6 m. For the real leg the limit is √(9.81 × 0.68) = 2.59 m/s.
| Asked for | Walked at | Pull needed, v²/L | Share of gravity |
|---|---|---|---|
| 0.4 m/s | 0.38 m/s | 0.21 m/s² | 2% |
| 0.8 m/s | 0.76 m/s | 0.84 m/s² | 9% |
| 1.6 m/s | 1.35 m/s | 2.66 m/s² | 27% |
- Its fastest clean walk uses only 27% of what gravity offers. The robot is limited by its controller and motors long before the pendulum limit.
- It takes about 2.5 steps a second at every speed. The policy's step clock is fixed, so it goes faster only by taking longer steps: 15 cm, 30 cm, 54 cm.
- The G1 walks with bent knees, so its hip rides a flatter arc than a stiff 0.68 m leg would give. The rigid pendulum is the textbook model, and a slightly cautious one.
Wrong answersWhy each one is tempting
| Pick | What went wrong |
|---|---|
| A · 0.6 | Leg length, relabelled. |
| B · 1.2 | Half the answer: the comfortable switch point, not the limit. |
| D · 4.8 | Double the answer, or g·L without the square root (5.9). |
Follow-ups an interviewer asks nextTry these before opening them
An adult has legs about 0.9 m long. Their walking limit?
√(9.81 × 0.9) = 2.97 m/s, about 10.7 km/h. Olympic race walkers reach 4 m/s only by rolling their hips so the centre of mass rides a much flatter arc than a stiff leg would give.
People and animals switch from walking to running at v²/(g·L) ≈ 0.5, not 1. Why so early?
The limit says when walking becomes impossible, not when it stops being efficient. Near 0.5 the vault gets so steep that running (bouncing on springy tendons) costs less energy. Horses, birds and humans all switch near the same number, which is the point of using a ratio.
Same robot on the Moon, g = 1.62 m/s². Fastest walk?
√(1.62 × 0.6) = 0.99 m/s. Gravity is too weak to hold the foot down at any useful speed, which is why the Apollo astronauts ended up hopping.
How could a robot walk faster without running?
Make the arc flatter than a rigid pendulum: bend the knee through the step, or roll the pelvis. That lowers the pull needed at a given speed. Most humanoid robots already walk with bent knees, for a different reason (straight knees are a control singularity).